Research

Selected work & papers

The question under all of it: how can embodied or resource-constrained agents build predictive internal models of the world, adapt continuously after deployment, and learn efficiently using local, predictive, or non-standard learning rules?

Selected projects
Nature Machine Intelligence · 2026 · First author under revision

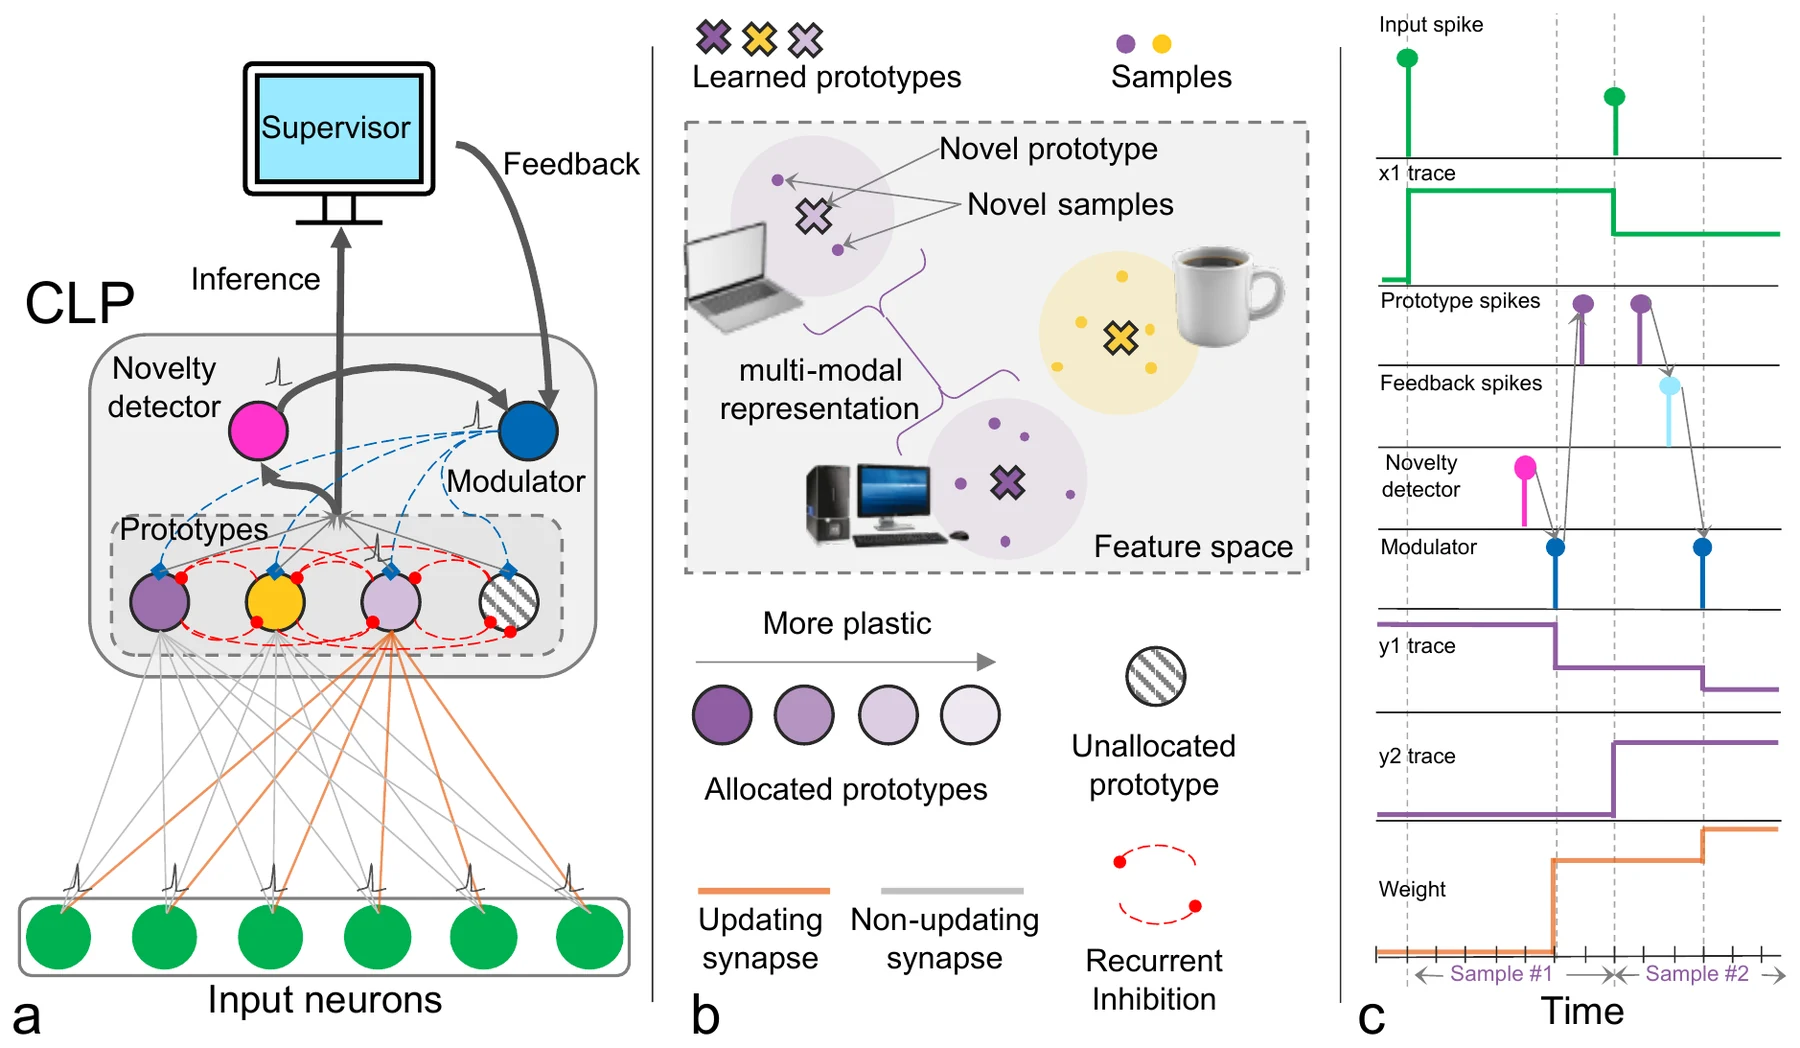
CLP-SNN: on-chip continual learning on Loihi 2

A spiking version of CLP, co-designed with neuromorphic silicon, that learns new classes from a data stream on the chip itself, without replay buffers or backpropagation.

  • 7.3×lower latency than Replay on Jetson Orin Nano
  • 341×lower energy, at comparable accuracy
  • 0.33 msper prediction-and-update step
ICANN · 2026 · First author accepted

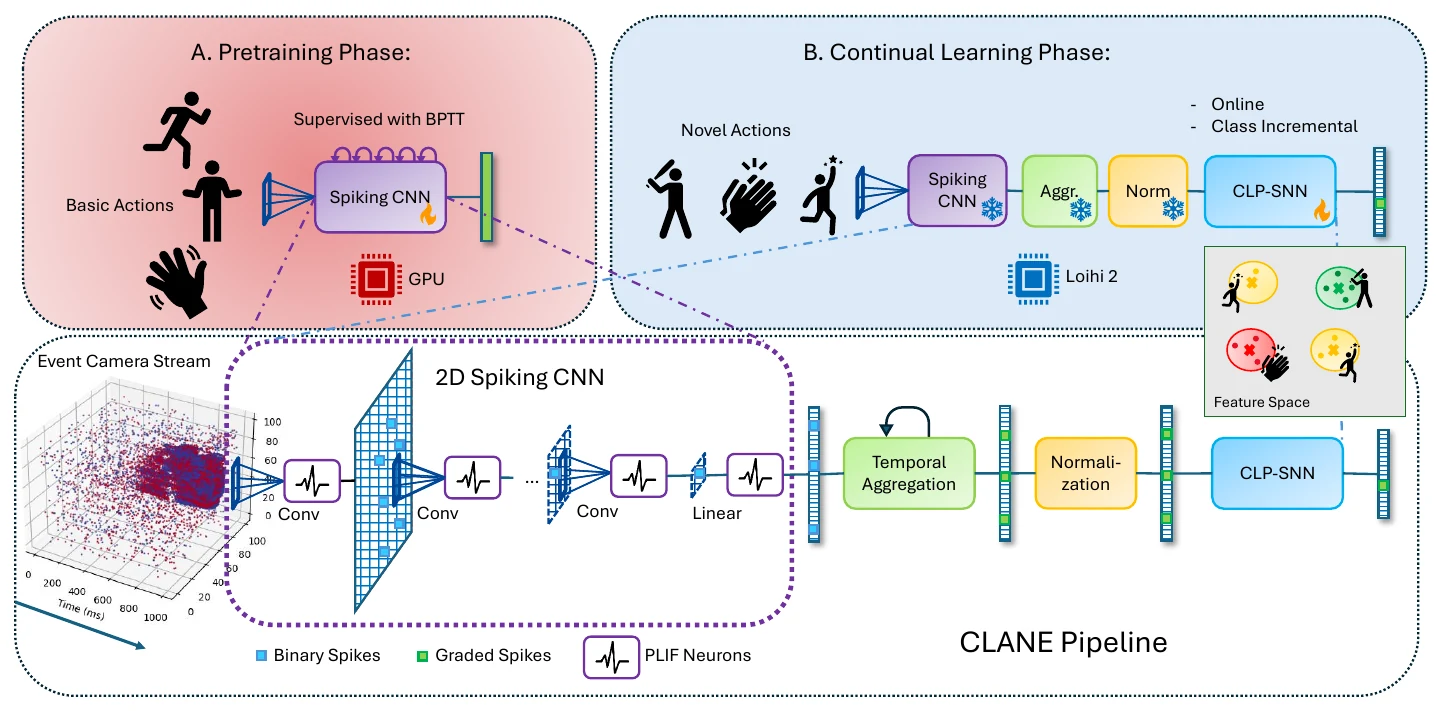
CLANE: learning new actions on-chip from event cameras

An end-to-end on-chip pipeline that learns new human actions from an event-camera stream, class-incrementally, without sending data off the device.

  • 16×lower latency than a Jetson Orin Nano pipeline
  • >100×lower energy than the same baseline
  • 5 msper sample, at mJ-level energy
IROS · 2024 · First author

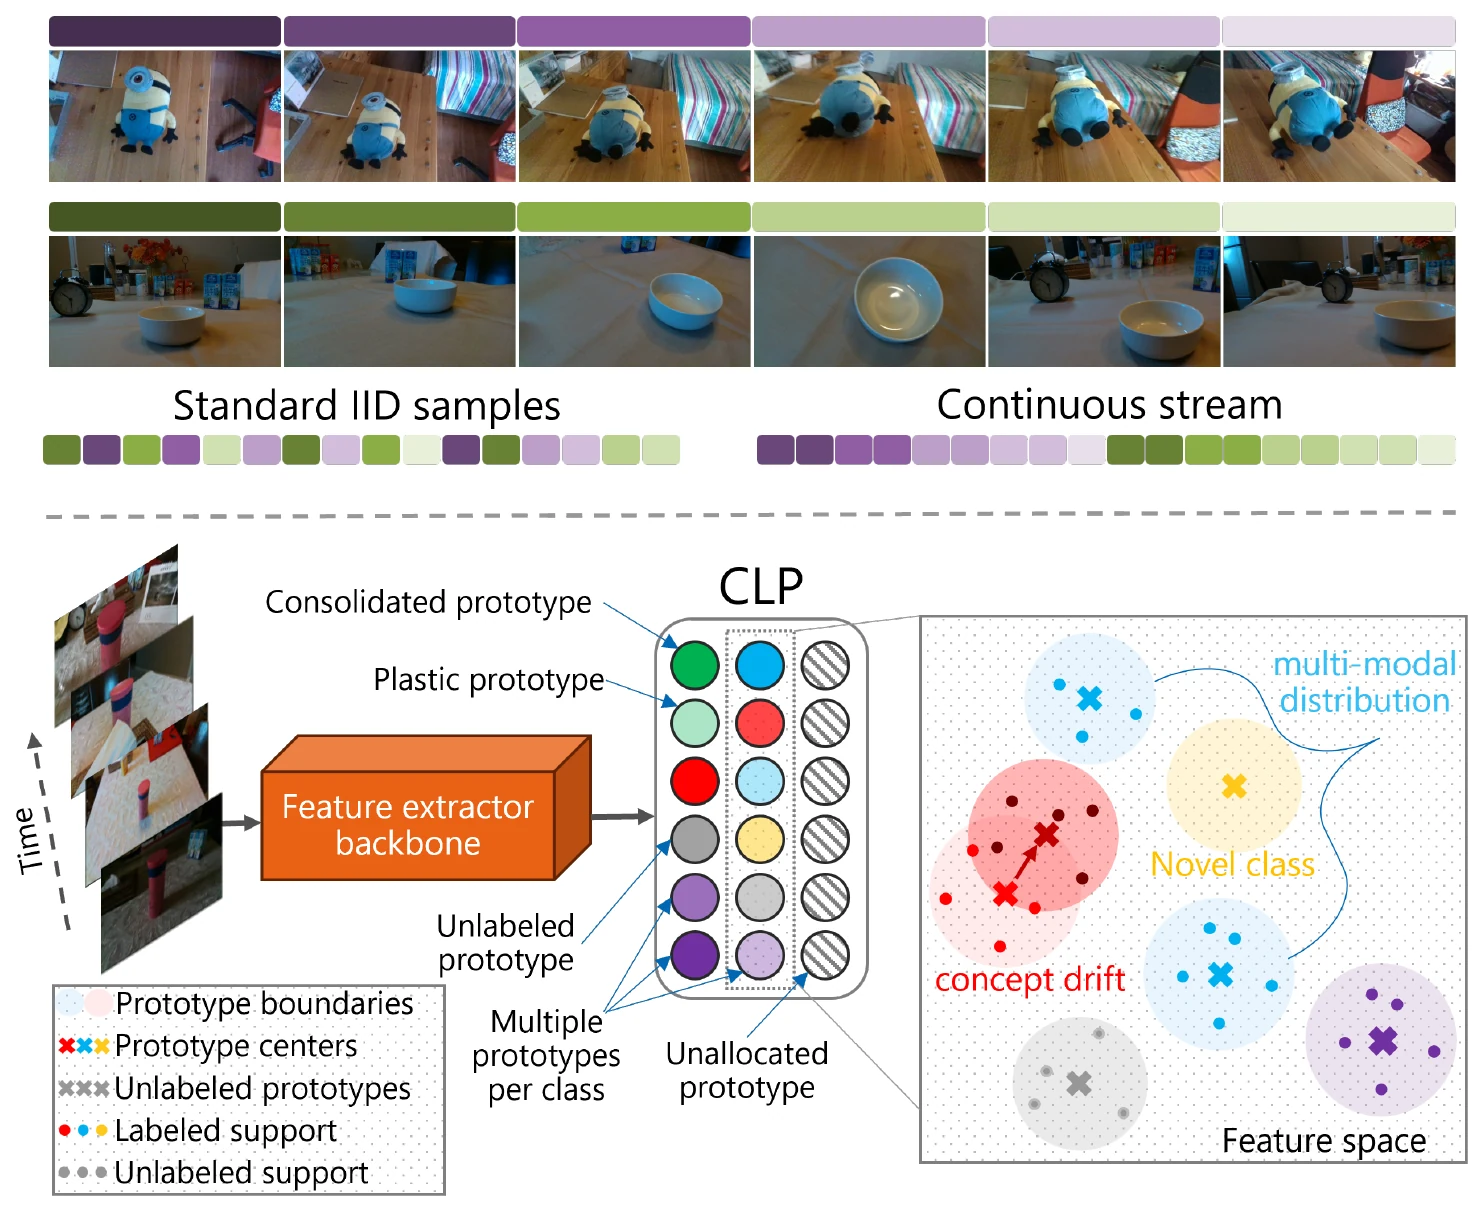
CLP: rehearsal-free continual learning for robots

A prototype-based online learner for robots that meet new objects after deployment: it learns from few labels, detects novel objects and keeps learning them without supervision, with no replay buffer.

  • 85%less catastrophic forgetting
  • 99%base-class accuracy in the open world
  • 65 / 76%novel-class accuracy (5 / 10-shot), learned without labels
ICONS · 2022 · First author Best Paper Award

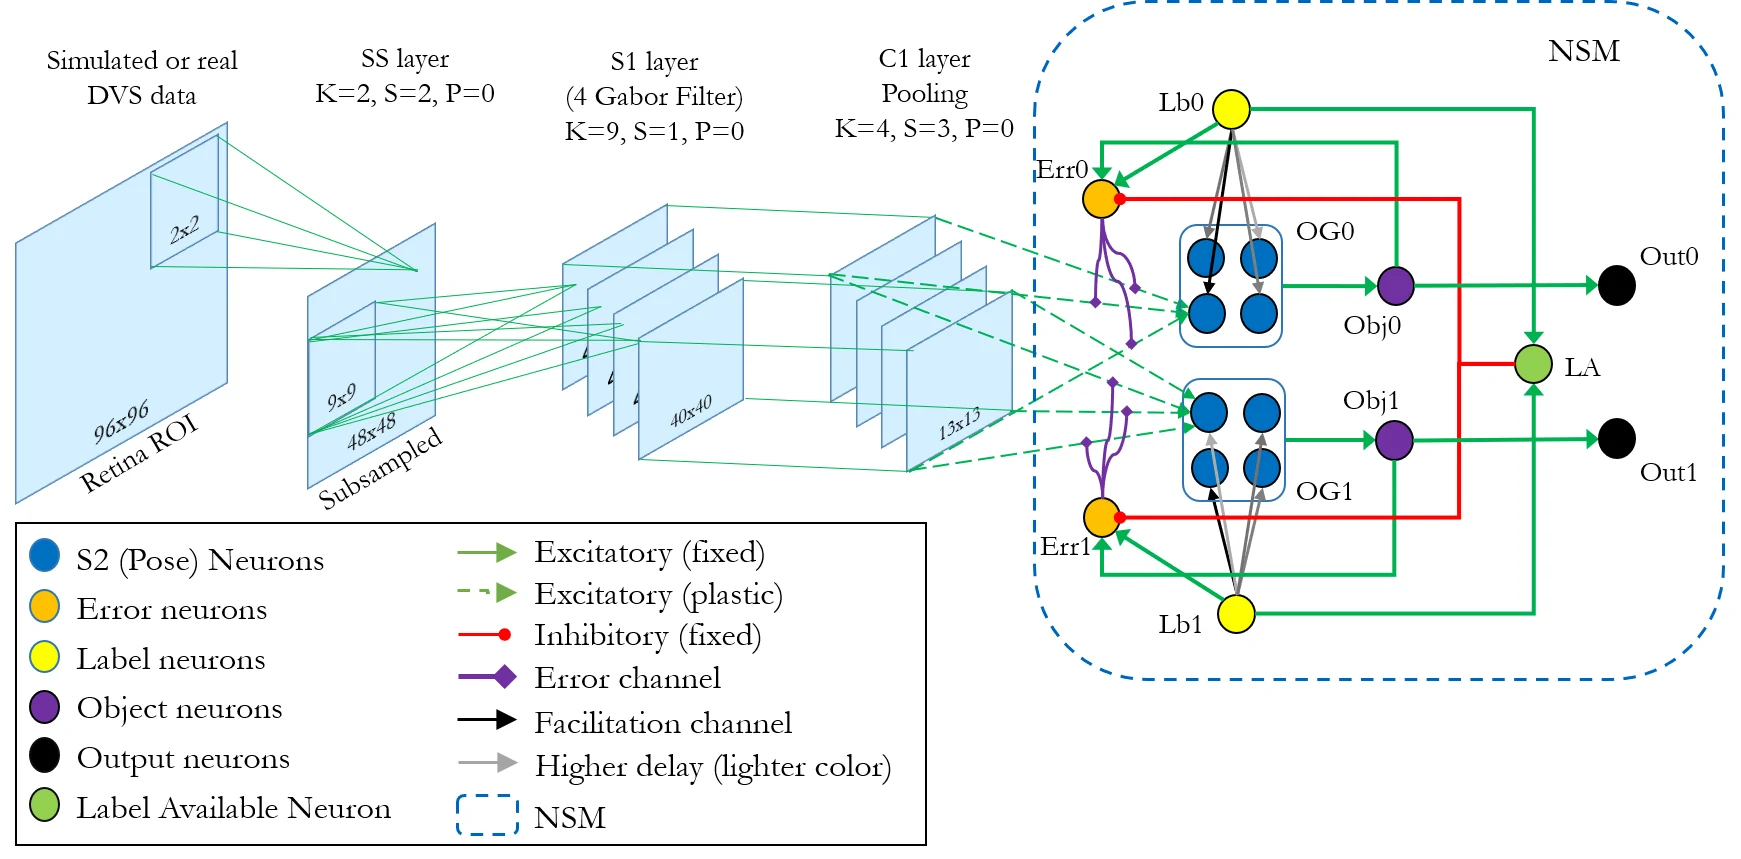
Interactive object learning on Loihi

A spiking network on Intel Loihi that learns new objects in a short interactive session with a user, with a neural state machine deciding on-chip when and how to learn.

  • 96.6%test accuracy, 8 objects × 8 views
  • up to 300×energy efficiency vs. other online learners
IROS · 2025 · Shared first author

Predictive coding that exploits temporal correlation

PCN-TA, a predictive-coding online learner that keeps latent states across consecutive frames of a sensory stream, cutting the cost that usually makes predictive coding expensive.

  • 10%fewer weight updates than backprop
  • 50%fewer inference steps than baseline PC
Now
2026 · in progress

Continual adaptation of a pretrained VLA on LIBERO

Fine-tuning the released SmolVLA LIBERO policy on new LIBERO-90 manipulation tasks in simulation and measuring how well its earlier skills are retained across continual-learning baselines. Planned extension: how low-bit compression changes what a VLA keeps under fine-tuning.

VLAContinual LearningManipulation
2026 · in progress

Predictive world models for robot manipulation

A compact, self-supervised predictive world model with continual learning across multiple time-scales, evaluated on the LIBERO manipulation benchmark. The question I'm chasing: can an agent keep adapting (at test time, across tasks, over its lifetime) instead of freezing the moment it ships?

Embodied AIWorld ModelsContinual Learning
Publications
Code & open source
Awards & recognition

Best Paper Award, ICONS 2022

Interactive continual learning for robots

Intel "Fearless Innovation" Award

2022

DAAD Scholarship

Master's studies, German Academic Exchange Service

Bernstein SMARTSTART Fellow

Computational Neuroscience

Full CV with the detailed record.
Download CV (PDF)